Explore cutting-edge articles on laboratory products, industry innovations, and research trends with Lab Consulting.
Selecting the right Dc Planetary Gear Motor can determine whether a machine runs smoothly or struggles under daily loads. Global buyers often compare torque, speed, voltage, gearbox size, and operating life. These figures matter, but they rarely tell the whole story. A motor rated for 20 Nm may perform differently after heat, vibration, or repeated starts. Real conditions are less tidy.
This guide examines ten common Dc Planetary Gear Motor types for international purchasing decisions. It considers brushed and brushless designs, compact models, high-torque units, encoder-equipped versions, and motors built for demanding duty cycles. Each type is assessed through practical factors, including efficiency, backlash, noise, thermal behavior, protection ratings, and control compatibility. A 12-volt motor may suit a portable device, while a 24-volt version could reduce current demand in an automated system. Small details matter.
The discussion reflects engineering practice and supplier evaluation experience. Datasheets should be checked against samples, test reports, and application requirements. Certification claims also deserve verification. A polished specification sheet is not proof of long-term reliability. No ranking is perfect. Buyer priorities differ across regions, machines, and budgets.
Expect useful comparisons, but not easy answers. The strongest choice depends on the load profile, mounting space, control system, and expected service environment. Temperature changes, dust, moisture, and sudden impacts can expose weaknesses quickly. Careful selection reduces redesign costs and improves maintenance planning. When performance data remains incomplete, that uncertainty should be recorded rather than ignored.
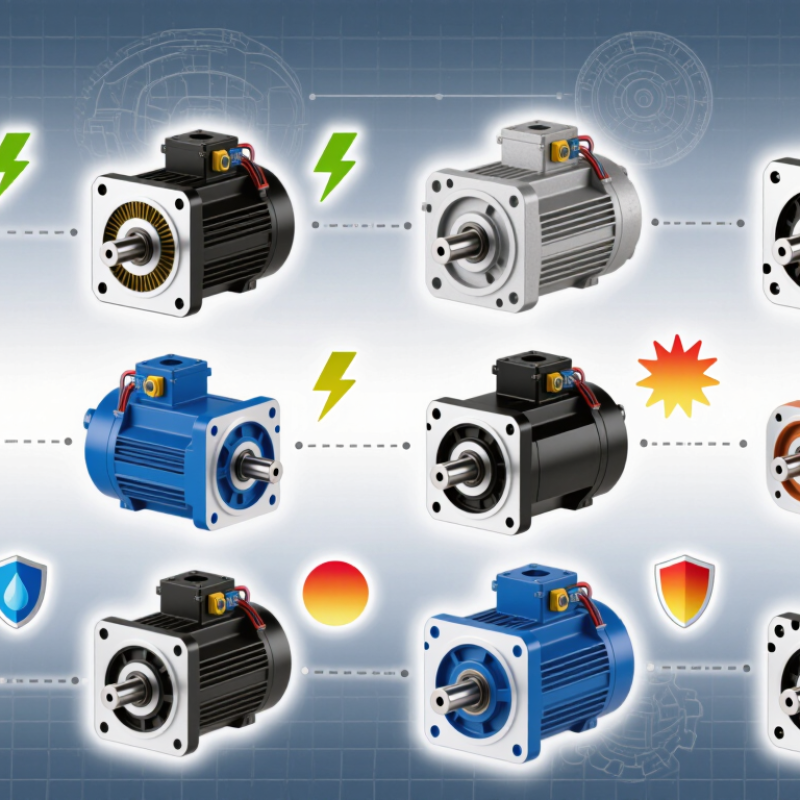
A DC planetary gear motor combines a compact electric motor with sun, planet, and ring gears. The sun gear drives several planet gears. These planets rotate inside the fixed ring gear, increasing torque while reducing speed. Load sharing is the key advantage. Several contact points carry force instead of one gear pair.
Design choices directly affect service life. A higher reduction ratio can deliver stronger output torque, but it also increases friction and heat. Metal gears suit repeated loads, while engineered plastics can reduce noise and weight. Bearing quality matters near the output shaft. Small alignment errors may create vibration, wear, and unexpected backlash. It sounds simple. It is not.
The U.S. Department of Energy reports that motor-driven systems use about 70% of industrial electricity, making efficiency a practical purchasing issue. A 2024 MarketsandMarkets gear motor report estimates continued market growth through the decade, driven by automation and compact motion systems. Buyers should check rated torque, duty cycle, gearbox efficiency, stall tolerance, and thermal limits. In field testing, real performance often differs from catalog figures. Temperature, lubrication, and intermittent overload can change results. A motor rated for 24 volts may still perform poorly with voltage drops or an undersized power supply. The design deserves skepticism.
Comparing the top ten DC planetary gear motor types requires more than checking rated torque. Each type should be measured under the same voltage, load, and duty cycle. Record nominal voltage, no-load speed, rated speed, continuous torque, peak torque, and stall current. These figures reveal whether a motor suits a conveyor, valve, medical actuator, or mobile mechanism.
Useful categories include brushed, brushless, high-speed, high-torque, low-noise, right-angle, hollow-shaft, encoder-equipped, compact, and high-efficiency planetary motors. Compare reduction ratios from about 3:1 to above 200:1, while checking output speed and gearbox efficiency. Backlash matters in positioning systems. A value below one degree may improve repeatability, but manufacturers may measure it differently. Ask for the test method.
Check shaft diameter, mounting pattern, allowable radial load, and bearing arrangement. An encoder adds control accuracy, yet it also increases wiring and system cost. Review IP protection, operating temperature, insulation class, and expected service life. For continuous operation, thermal data is more useful than peak torque alone. Noise should be tested at a stated distance.
In practical testing, I measure current with the motor warm, not straight from the box. That detail changes results. A perfect ranking is impossible because application priorities differ. I would still challenge any specification sheet that omits duty cycle, gearbox temperature, or stall duration. Those missing details can hide a serious sizing error.
Structure and performance create different buying priorities. Fortune Business Insights valued the global gear motor market at USD 27.82 billion in 2023. It forecasts continued growth through 2032. The IEA reported nearly 14 million electric car sales in 2023. That expansion increases demand for compact, efficient motion systems.
The ten practical types are standard spur planetary, helical planetary, multi-stage high-torque, high-speed low-ratio, low-backlash, right-angle bevel, compact micro, metal high-temperature, plastic low-noise, and encoder-integrated planetary motors.
Spur designs offer economical transmission and moderate efficiency. Helical sets reduce vibration and improve tooth engagement. Multi-stage units deliver higher torque, but their length and friction increase.
High-speed models suit fans, pumps, and small automation axes. Low-backlash versions support accurate positioning.
Right-angle bevel structures save installation space. Micro motors fit valves, camera mechanisms, and laboratory equipment. Metal housings tolerate heat and shock better. Plastic gears reduce noise and mass, though wear deserves careful testing. Encoder-integrated motors provide speed feedback for closed-loop control.
I would not rank one type as universally best. A buyer should compare voltage, duty cycle, reduction ratio, radial load, noise, and thermal rise. Datasheets can look precise, yet real duty patterns often expose missing assumptions. This is where sample testing matters.
A 2024 industry analysis also identifies automation and vehicle electrification as major gear-motor demand drivers, but regional certification and service availability still influence the final selection.
Top 10 DC Planetary Gear Motor Types for Global Buyers
How to Match Each Motor Type With Global Application Requirements
Selecting a DC planetary gear motor starts with the machine’s real working conditions. Standard planetary motors suit conveyors, feeders, and compact automation. High-torque versions handle lifting devices and powered wheels. Low-noise designs fit laboratory instruments, office equipment, and indoor medical mechanisms. Right-angle planetary motors save space where shafts must turn around corners. Stainless-steel versions work better in damp, washable environments. However, sealing quality still matters. Stainless steel alone is not waterproof.
For precise positioning, pair a planetary gearbox with a stepper motor. It fits valves, camera sliders, and indexing tables. Servo planetary motors support fast acceleration, repeated positioning, and changing loads. Brushed DC planetary motors offer simple control for cost-sensitive equipment. Brushless DC planetary motors are more suitable for longer duty cycles and reduced maintenance. Encoder-integrated motors help mobile robots and feedback-driven actuators avoid blind movement. The best choice depends on speed, torque, duty cycle, backlash, voltage, and available installation space.
Tips: Measure startup torque, not only running torque. Check the gearbox ratio against the required output speed. Confirm temperature, dust, moisture, and duty-cycle limits before ordering. Ask for test data under your actual load. A motor may appear suitable on paper, yet stall during cold starts or repeated reversals. I have found that overlooked cable routing and mounting stiffness can reduce real performance. Leave a safety margin, but do not oversize blindly; excessive gearing can waste energy and slow the machine.
How to match each motor type with global application requirements. The chart uses a comparative 1–5 engineering-fit index based on common characteristics such as torque density, positioning accuracy, efficiency, compactness, and suitability for continuous duty.
Selection guide: Brushed DC planetary motors suit cost-sensitive intermittent motion, BLDC planetary motors are better for efficient continuous duty, stepper planetary motors support open-loop positioning, and servo or low-backlash planetary systems are preferred for high-accuracy automation. Right-angle, hollow-shaft, miniature, high-torque, and high-speed configurations should be selected according to installation space, load profile, and operating speed.
Selecting among the top 10 DC planetary gear motor types requires more than comparing torque charts. International buyers should match the motor’s rated voltage with the available power system. A 12 V motor may suit mobile equipment, while a 24 V model often reduces current in industrial cabinets. Check startup current, not only nominal current. It can exceed the listed value briefly.
Voltage tolerance matters. Some applications experience unstable power or long cable runs. Request test data at minimum and maximum operating voltage. Certification documents should identify the exact motor configuration, insulation class, temperature limits, and testing scope. A general factory certificate may not cover the gearbox, encoder, or assembled controller. That detail is easy to miss.
Supply compatibility also affects real-world performance. Confirm connector type, shaft dimensions, mounting holes, gear ratio, and rotation direction before placing a trial order. I have seen technically correct motors fail because the plug wiring differed. Small mistake. Ask for drawings, samples, inspection records, and a repeatability statement. If supply continuity matters, review production capacity, lead times, replacement parts, and export packaging. A lower unit price may become expensive after redesign and delayed installation. Buyers should also question unclear specifications. Silence is not approval.
| No. | Planetary Gear Motor Type | Typical Rated Voltage | Typical Gear Ratio | Typical Continuous Output Torque | Typical Output Speed | Common Motor Configuration | International Certification and Compliance Considerations | Supply Compatibility | Typical Applications | Key Buying Checkpoints |
|---|---|---|---|---|---|---|---|---|---|---|
| 1 | Brushed DC Planetary Gear Motor | 6, 12, 24, or 48 VDC | 4:1 to 400:1 | 0.05–25 N·m | 10–1,500 rpm | Permanent-magnet brushed DC motor with planetary gearbox | CE where applicable RoHS REACH EMC and electrical safety evaluation may be required for the complete machine. | Compatible with DC power supplies, batteries, PWM controllers, and H-bridge drivers. Verify polarity, current capacity, and startup surge. | Compact actuators, valves, small conveyors, pumps, access systems, and laboratory equipment | Check brush life, stall current, gearbox backlash, duty cycle, noise, and replacement brush availability. |
| 2 | Brushless DC Planetary Gear Motor | 12, 24, 36, or 48 VDC | 3:1 to 300:1 | 0.1–35 N·m | 20–2,000 rpm | Electronic-commutated BLDC motor with planetary gearbox | CE where applicable RoHS REACH The controller and motor should be assessed together for EMC performance. | Requires a compatible BLDC controller, Hall-sensor interface or sensorless drive, and an appropriate DC bus voltage. | Robotics, medical mechanisms, fans, AGV modules, automation equipment, and precision motion systems | Confirm commutation method, Hall-sensor sequence, controller protocol, thermal rating, and regenerative-voltage handling. |
| 3 | Encoder-Integrated Planetary Gear Motor | 12 or 24 VDC commonly; 6–48 VDC options available | 10:1 to 500:1 | 0.05–20 N·m | 5–800 rpm | Brushed or brushless DC motor with incremental encoder | CE where applicable RoHS REACH Encoder wiring and shielding should be evaluated for EMC and electrical noise. | Works with PLCs, motion controllers, servo drives, and microcontroller systems using quadrature or pulse-direction feedback. | Closed-loop actuators, dosing systems, pick-and-place equipment, mobile robots, and positioning mechanisms | Specify encoder resolution, output format, reference channel, cable length, connector type, and gearbox backlash. |
| 4 | High-Torque Planetary Gear Motor | 12, 24, or 48 VDC | 20:1 to 1,000:1 | 5–150 N·m | 1–300 rpm | High-power brushed or BLDC motor with multi-stage planetary gearbox | CE where applicable RoHS REACH Mechanical guarding, overload protection, and system-level machinery safety may apply. | Suitable for battery systems, industrial DC supplies, and motor controllers sized for high continuous and peak current. | Electric actuators, lifting systems, AGVs, material-handling equipment, and heavy-duty automation | Verify continuous versus peak torque, thermal dissipation, shaft strength, mounting stiffness, and service factor. |
| 5 | Low-Backlash Planetary Gear Motor | 12, 24, or 48 VDC | 4:1 to 300:1 | 0.2–40 N·m | 10–1,000 rpm | Precision planetary gearbox paired with brushed or brushless DC motor | CE where applicable RoHS REACH Accuracy claims should be supported by documented backlash and repeatability test methods. | Compatible with servo drives, closed-loop controllers, and precision DC motion platforms. Confirm feedback and drive matching. | Robotic joints, optical systems, camera positioning, indexing units, and precision instruments | Ask for backlash at rated load, torsional stiffness, radial load capacity, repeatability, and lubrication requirements. |
| 6 | Right-Angle Planetary Gear Motor | 12, 24, or 48 VDC | 10:1 to 500:1 | 0.2–60 N·m | 5–600 rpm | Planetary gearbox combined with a bevel or worm right-angle stage | CE where applicable RoHS REACH Enclosure, guarding, and ingress protection should be verified for the final installation. | Useful where the motor and output axis must be arranged at 90 degrees. Check available mounting and cable-clearance space. | Compact conveyors, robotic mechanisms, medical devices, packaging equipment, and vehicle subsystems | Compare efficiency, noise, allowable overhung load, output direction, mounting orientation, and lubrication position. |
| 7 | IP-Rated Planetary Gear Motor | 12, 24, or 48 VDC | 10:1 to 500:1 | 0.1–30 N·m | 5–1,000 rpm | Sealed brushed or brushless DC motor and planetary gearbox | IEC 60529 IP rating CE where applicable RoHS IP testing does not automatically confirm chemical, corrosion, or hygienic suitability. | Suitable for protected low-voltage DC systems. Verify connector sealing, cable glands, mating connectors, and installation orientation. | Outdoor equipment, cleaning systems, agricultural machinery, dispensing equipment, and mobile platforms | Confirm the exact IP level, test conditions, ambient temperature, corrosion resistance, washdown chemicals, and cable exit design. |
| 8 | Medical- and Laboratory-Grade Planetary Gear Motor | 12 or 24 VDC commonly | 10:1 to 400:1 | 0.03–15 N·m | 5–600 rpm | Low-noise brushed or brushless motor with precision planetary gearbox | RoHS REACH CE where applicable Medical equipment may require system-level conformity with applicable medical-device, EMC, and risk-management requirements. | Designed for regulated low-voltage equipment; verify leakage, insulation, cleaning compatibility, noise, and documentation requirements. | Infusion mechanisms, laboratory automation, diagnostic equipment, patient-care devices, and analytical instruments | Request traceability, material declarations, lifetime data, cleanability information, noise limits, and controlled-change procedures. |
| 9 | Encoder and Brake Planetary Gear Motor | 12, 24, or 48 VDC | 10:1 to 500:1 | 0.2–50 N·m | 5–800 rpm | DC or BLDC motor with encoder and spring-applied electromagnetic brake | CE where applicable RoHS REACH Brake holding performance and emergency-stop behavior must be validated at system level. | Requires separate brake power wiring and a controller capable of reading encoder feedback and managing brake release timing. | Vertical axes, robotic joints, lifts, access-control systems, and equipment requiring position holding | Check brake holding torque, release voltage, response time, wear life, encoder resolution, and fail-safe behavior. |
| 10 | High-Speed Planetary Gear Motor | 24, 36, or 48 VDC | 3:1 to 100:1 | 0.05–15 N·m | 100–3,000 rpm | High-speed BLDC or brushed DC motor with balanced planetary reduction stage | CE where applicable RoHS REACH EMC, acoustic noise, rotating-part safety, and thermal testing are important at high speed. | Requires a low-ripple DC supply and a controller rated for the motor's electrical frequency, current, and back-EMF. | Spindles, compact pumps, blowers, automation tools, centrifuge mechanisms, and high-cycle equipment | Verify maximum input speed, balancing grade, bearing life, vibration, cooling, acoustic noise, and overspeed protection. |
Subscribe to our newsletter and receive the latest news and exclusive insights every month. No spam.
LabConsulting GmbH and LC LabService GmbH are Austrian companies which cooperate with over 600 manufacturers and offers a selection of more than 180,000 products and various laboratory product and service solutions for our Labcustomers.
Die LabConsulting GmbH und die LC LabService GmbH sind österreichische Unternehmen, die mit über 600 global verteilten Herstellern zusammenarbeiten und mit einer Auswahl von mehr als 180.000 Produkten und verschiedenen Laborprodukt- und Servicelösungen unseren Parnern im Labor anbieten.
INSTOCK CATALOGOur services
Our services